讲座介绍
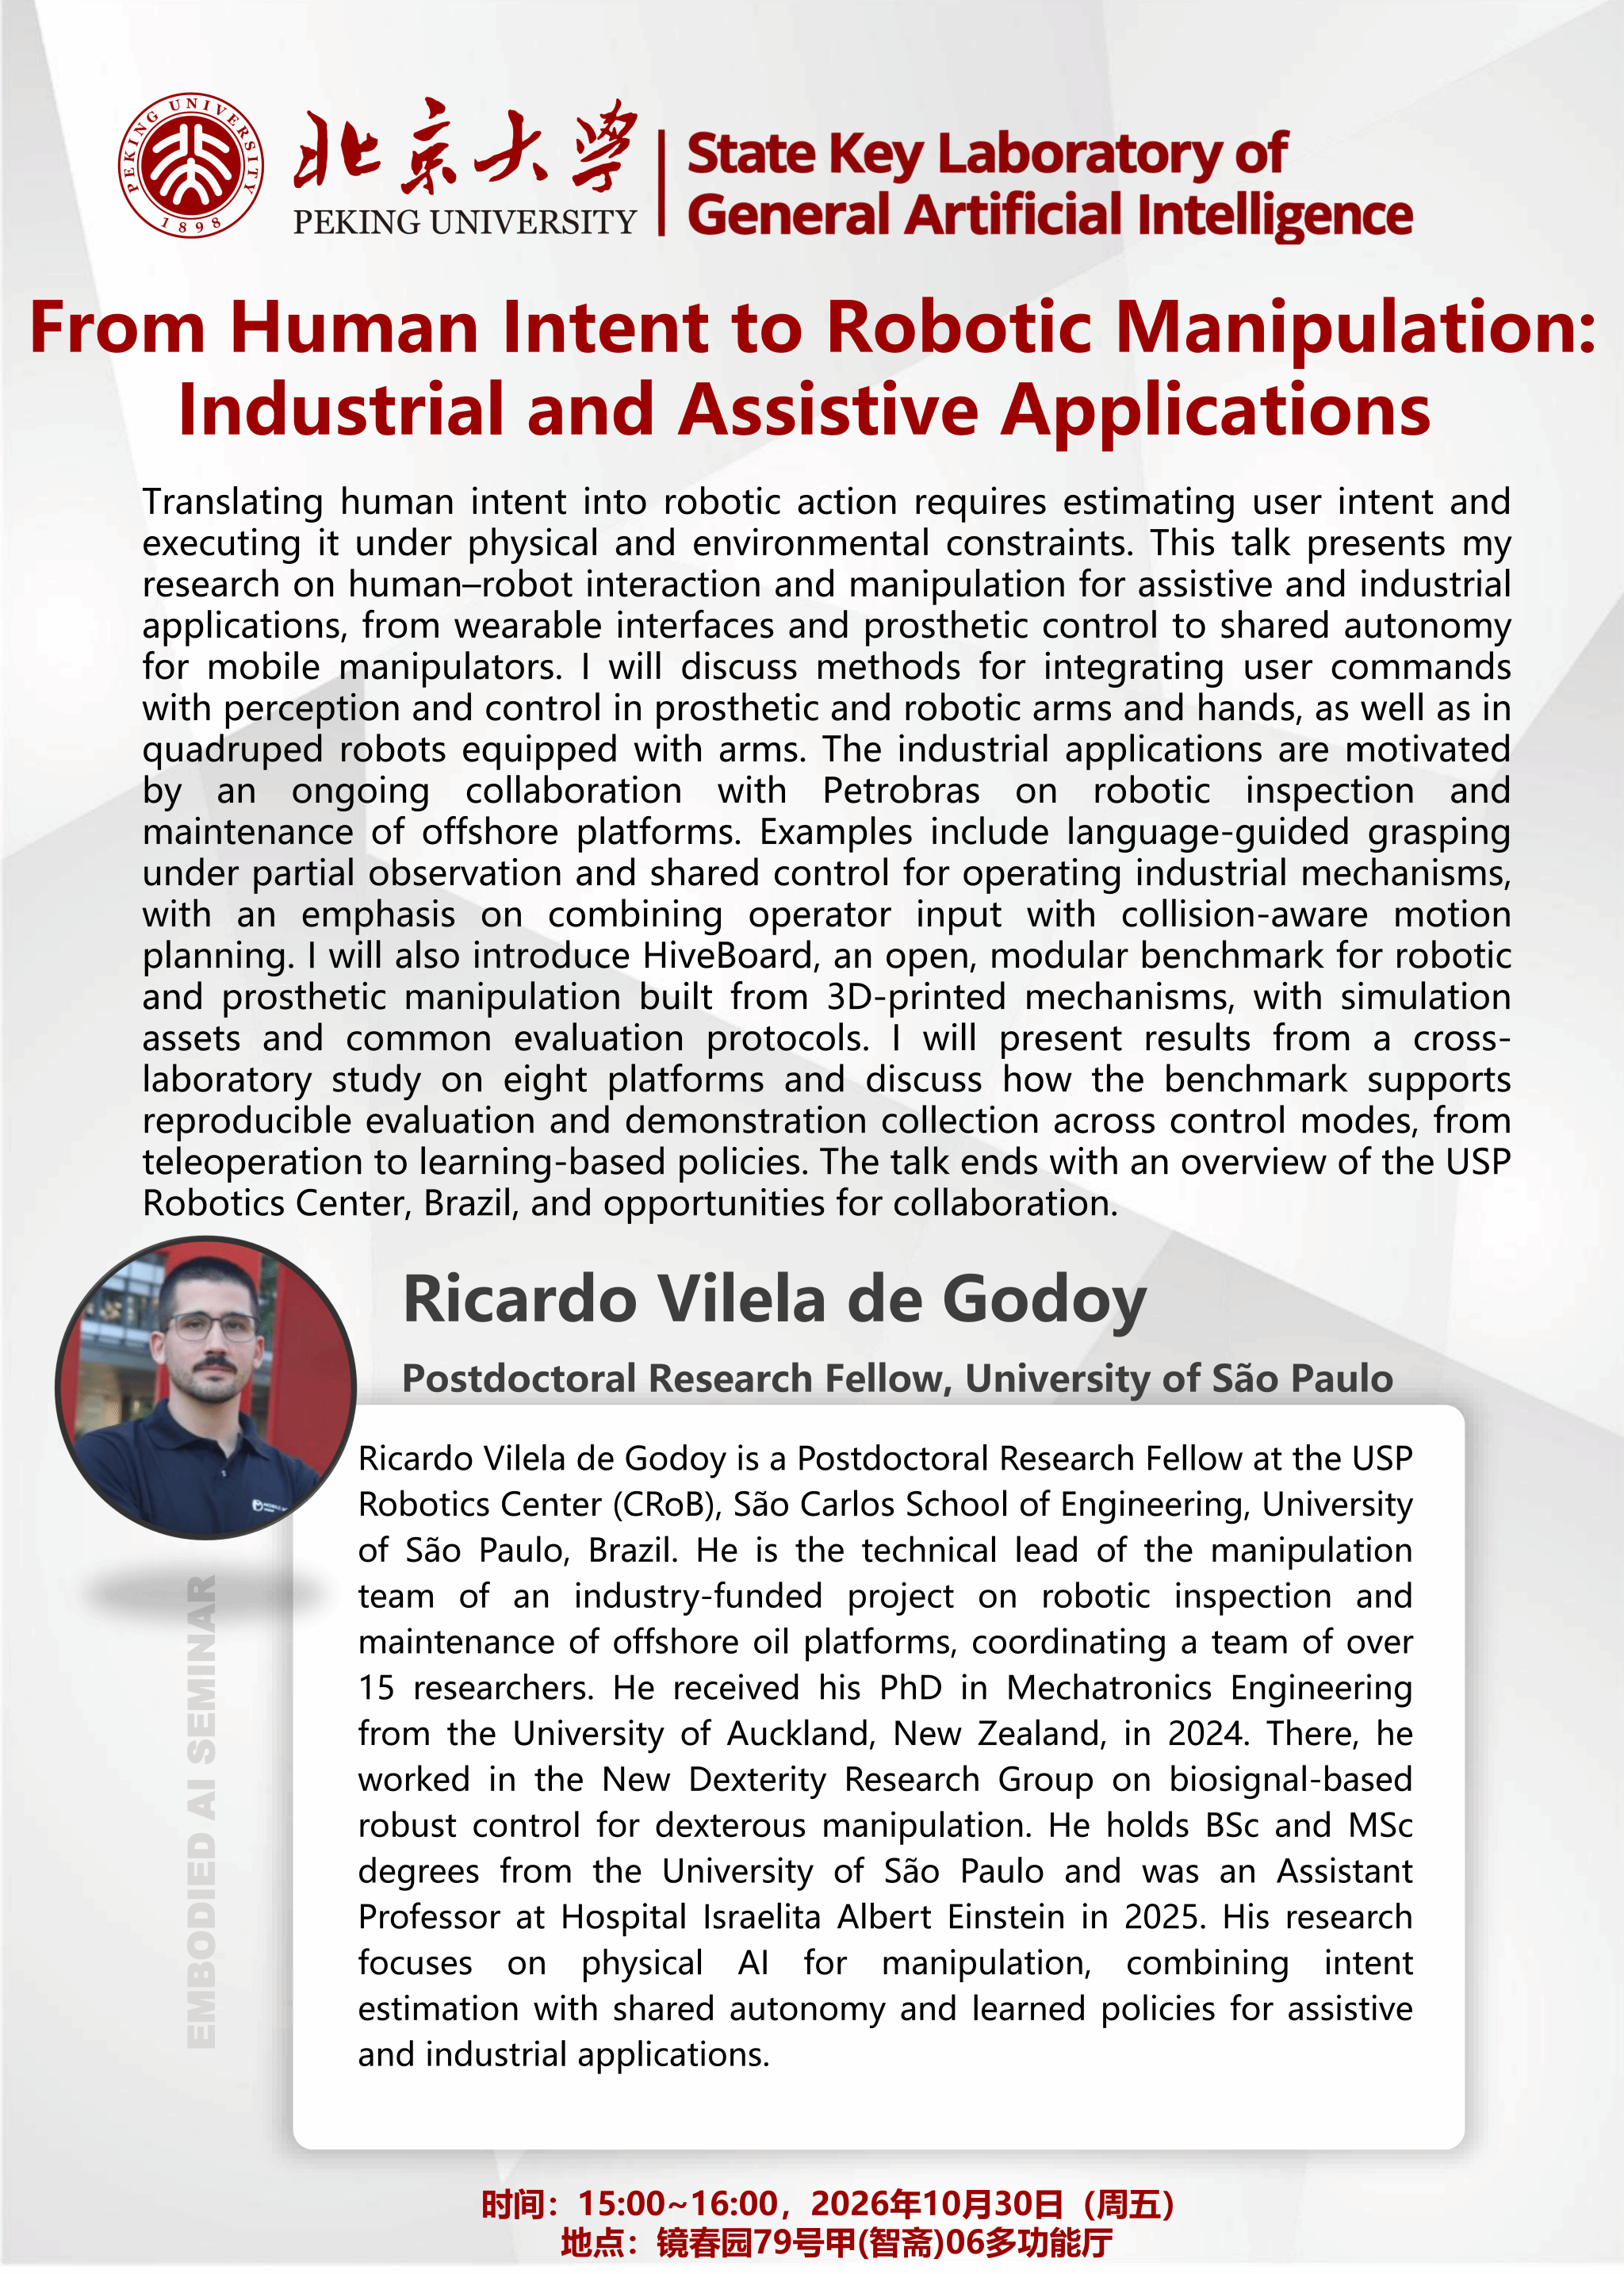
Translating human intent into robotic action requires estimating user intent andexecuting it under physical and environmental constraints. This talk presents myresearch on human-robot interaction and manipulation for assistive and industrialapplications, from wearable interfaces and prosthetic control to shared autonomyfor mobile manipulators. I will discuss methods for integrating user commandswith perception and control in prosthetic and robotic arms and hands, as well as in quadruped robots equipped with arms. The industrial applications are motivated by an ongoing collaboration with Petrobras on robotic inspection andmaintenance of offshore platforms. Examples include language-guided graspingunder partial observation and shared control for operating industrial mechanisms, with an emphasis on combining operator input with collision-aware motionplanning. I will also introduce HiveBoard, an open, modular benchmark for robotic and prosthetic manipulation built from 3D-printed mechanisms, with simulationassets and common evaluation protocols. I will present results from a cross-laboratory study on eight platforms and discuss how the benchmark supportsreproducible evaluation and demonstration collection across control modes, fromteleoperation to learning-based policies. The talk ends with an overview of the USPRobotics Center, Brazil, and opportunities for collaboration.
报告人
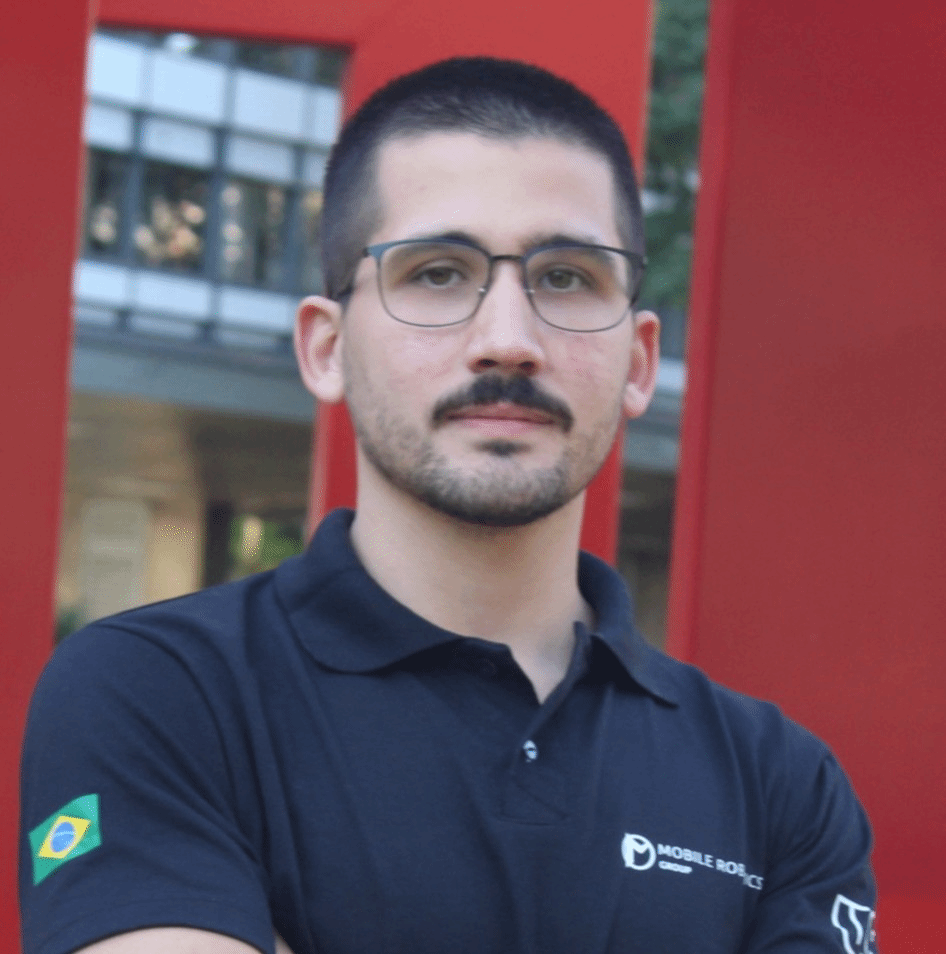
Ricardo Vilela de Godoy
Postdoctoral Research Fellow
University of São Paulo
报告信息
时间:2026年10月30日 15:00 - 16:00
地址:镜春园79号甲(智斋)06多功能厅
主持人
刘航欣 助理教授
北京大学智能学院